Thursday, November 21, 2019

Current and voltage we need to supply to the stepper motors

So you’ve decided how many stepper motors you need and the torque rating. It’s then just a matter of matching to a suitable controller. All controllers will have stepper drivers that either individual modules or integrated into the controller board. The digital stepper drivers are designed to supply current and voltage, which in most cases is adjustable. It’s important to match the current with the stepper motor. Stepper motors can work at very low voltages but they are usually driven at much higher voltages up to 8 times by a chopper driver. If you would like more information check this link This gives higher torque and speed.

Current and voltage we need to supply to the stepper motors


If you use a stepper that needs 2.8 amps and your drivers only supplies 1.5 amps it may still work but slowly and may not be enough to overcome the load.

Generally, NEMA17’s are run on 12 volts and NEMA23 24 volts. If you supply less then the motors will turn slowly. Its to do with something called back EMF. So when you are deciding on the controller check the current rating of the steppers and make sure the controller or driver modules can be adjusted to match as close as possible but don’t supply more or the motor may fail.

My foam cutter uses 57BYGH56-401A NEMA 23 which are rated at 2.8 amps and 3.36 Volts per phase. I run this with a 24-volt power supply and the current is at 2.25 amps set via DIP switches on the board. This has run for several years without any issues

Power Supply
The CNC power supply needs to be able to deliver the voltage and current for your chosen motors and controller. Going bigger on the current won’t hurt but the voltage needs to match the controller’s voltage. So for my foam cutter, I use 4 x 23HS22-2804S NEMA 23 rated at 2.8 amps and the controller need 2 amp. So 4 x 2.8 amps plus 2 amps for the controller gives 13.2 amps. If we multiply that by 24 volts to give Watts that comes to 316.8 Watts. Powers supplies can be rated by Amps or Watt so I use a 15 Amp 350 Watt supply.

CNC controllers for the DIY machine

Friday, November 15, 2019

Stepper Motors For Hot Wire CNC Foam Cutters

When we cut foam with a hot wire foam cutting machine it’s not actually being cut but melted.  Its referred to as cutting by radiance.  So the load on the steppers motors is virtually nothing from the hot wire if its temperature and feed rate are correct.  Nearly all of the load comes from the weight of the moving parts of the machine.

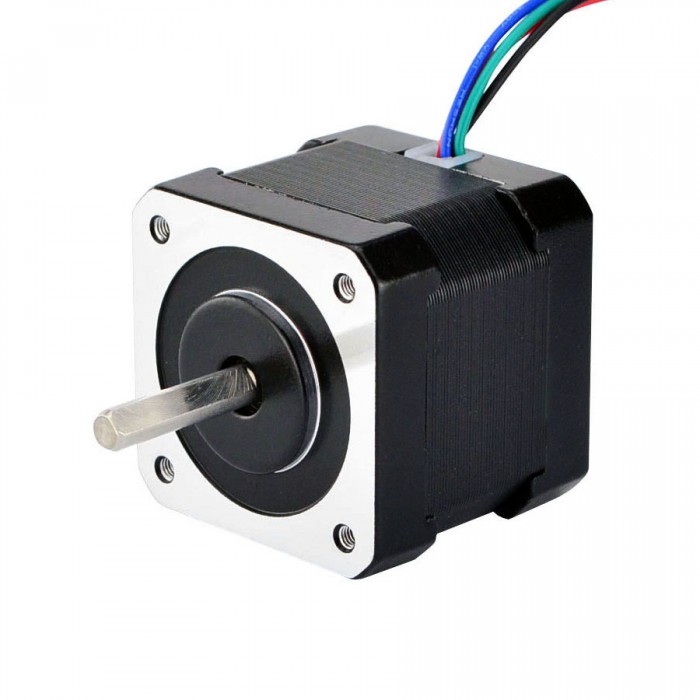
Nema Size 17 Stepper Motor Bipolar 45Ncm (64oz.in) 2A 42x40mm 4 Wires w/ 1m Cable & Connector for DIY 3D Printer CNC Rob

So NEMA17’s should be fine if your machine is not too heavy, something around 50-80 oz/in should be OK.  Vortec RC uses NEMA17 on their kit. www.vortex-rc.com/product/4-axis-diy-hot-wire-cnc-for-rc-hobbyists-aeromodellers-and-designers/
FoamLinx offer several machines but these are not really aimed at hobbyist, costing several thousand dollars. However, we can see they are using NEMA23 rated at 220oz/in on their small machine.


My current CNC foam cutter uses NEMA23 motor 175oz/in rated at 2.8 Amps. The moving parts on my build weigh a little over 11KG or 25 lbs, so it’s a bit on the heavy side. It’s made from 3/4″ (18mm) High-Density FIbreBoad(HDF) which is very strong and stable but quite heavy. So I decided to use the bigger stepper motors with the recommended 24 Volt power supply.

My updated design for 2019 which will use 12mm MDF and features several changes and improvements. It reduces weight considerably and allows the use of NEMA17 steppers. Keep checking back for the updated design should be out soon.

http://www.apsense.com/article/whats-the-difference-among-4wire6wire8wire-step-motor.html
https://www.techsite.io/p/1278002


Wednesday, November 13, 2019

How to Prevent Step Loss of Stepper Motor

The use of stepper motors is an excellent choice. However, a key concern is step losses. Step losses can be prevented or corrected in most instances.prevent step loss in stepper motors.

How to Prevent Step Loss of Stepper Motor


Stepper motors for sale operate open loop.  When a stepping motor does not operate correctly in a specific situation, the common conclusion is that either the drive electronics or the motor is faulty. The motor selection and the choice of the driver are critical.  However, other factors contribute to step losses.

The following points are important to examine for the analysis of step losses or non-operation in a methodical fashion across a variety of applications:

Stepper Motor Selection
Motion profile
Start-Stop operation
Trapezoidal profile
External commutation errors
External events
Back driving
Increase of the pay load over time

Stepper Motor Selection
The first task is to select the right stepper motor for the application. For the best selection, those basic theoretical rules have to be respected:

Select the motor based on the highest torque/speed point required by the application (selection based on the worst case)
Use a 30% safety factor from the published torque vs. speed curve (pull-out curve).
Ensure that the application cannot be stalled by external events
It is important to remember that a stepper motor does not operate like a DC motor. There is no working point parameterization, and the phase current does not increase to overcome variations of load. As long as the speed vs. torque requirement of the application is within the specs of the motor, no problem will be encountered. If this requirement is out of the specs, the motor stalls (OK or NOT OK functionality). In any case, the current in the phases is not changing and adapting by itself to the situation.

To read the complete technical paper and learn more about how to prevent step losses and tips for troubleshooting, download the free 4-page pdf now by clicking the button below.

What's the Difference Among 4-Wire,6-Wire,8-Wire Step motor
The difference Bettween 1-phase, 2-phase and 3-phase Motor


Friday, November 8, 2019

Related to one-two phase-on stepper driving is microstepping

A stepper drive is the driver circuit that controls how the stepper motor operates. Stepper drives work by sending current through various phases in pulses to the stepper motor(23hs45-4204s, 17hs16-2004s1.) There are four types: wave drives (also called one-phase-on drives), two-phase on, one-two phase-on drives and microstepping drives.
Microstepping delivers very fine motion resolutions. Here, the drive uses current regulation to prevent torque oscillations. With this technique, engineers can use stepper motors in more applications.
In sort, a drive that is microstepping increases and decreases current along a sine wave, so no pole is fully on or off. Here is a sample microstepping sine-wave current:
Stepper Drive Microstepping Current Sine-Wave
Note the subtle jagged contour of the sine-wave current. While microstepping doesn’t necessarily improve accuracy, it does get higher resolution than other driving modes—which is particularly helpful for applications in which the motor goes through no-load situations. During operation, motors can miss steps. However, microstepping spreads energy out instead of delivering it to the motor all at once, which can cause ringing and overshoot.
For all of these forms of driving, the motors can have different windings. Unipolar stepper motors nema 17 only accept positive voltage. Unipolar requires an extra wire in the middle of every coil to let current flow from one end to the other. Bipolar stepper motors use both positive and negative voltage. Bipolar stepper motors have more torque because they produce a stronger magnetic field, but their construction also requires more wire.

Friday, November 1, 2019

Safe Installation of Stepper Motor for 3D Printer

Installing steppers is a fairly straightforward process thanks to the standardized connectors used by most manufacturers. Simply plug the motor into the correct slot of the control board, and you should be good to go. However, there are still a few things to watch out for:

Safe Installation of Stepper Motor for 3D Printer


First, never install a motor (or anything, for that matter) on a printer while it is on and plugged in. This is hazardous because if done incorrectly, you risk shocking yourself, frying delicate components, and starting an electrical fire. So please, power off the printer and unplug it before commencing work.

Second, never unplug a step motor that is being powered. If you paid attention to the first step, this isn’t a problem, but if you didn’t, you’ll likely end up frying your stepper driver, and possibly your control board.

Third, ensure your digital stepper drivers are supplying the correct amount of current to the motors. This can be adjusted through the potentiometers on the driver board, or in some cases through the software of the printer. Too little current means the motor won’t have the proper torque, and too much can cause it to overheat.

Lastly, if you notice anything obviously wrong with the operation of the motor after installation, stop whatever you are doing and power down the printer. Carefully examine your wiring and driver circuit to ensure there are no mistakes before continuing to use the motor (if there aren’t any, make sure the motor, driver, and software are all compatible). This is a safe habit to assume while working with electronics to avoid fires and fried components.

Code Explanation to control Nema 17 with Arduino
Circuit diagram to control Nema17 stepper motor with Arduino


Wednesday, October 30, 2019

NEMA 34 Size Motor Applications and Dimensions

NEMA 34 is a high torque hybrid bipolar stepping motor with a 3.4×3.4 inch faceplate. Hybrid stepper has the combination of the features of the Variable Reluctance Stepper Motor and Permanent Magnet Stepper Motor. This motor has a step angle of 1.8 deg., this means that it has 200 steps per revolution and for every step it will cover 1.8°.  This NEMA 34 is a 2-Phase motor with 4 wires. Compatible controllers for this motor are CW230, CW250 and CW860.


How to use NEMA 34 Stepper Motor
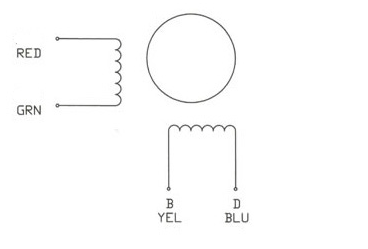
As mentioned above this stepper motor draws high current so instead of controlling it directly, use an appropriately powerful stepper motor drivers like cw230. Wiring diagram for NEMA 34 Stepper motor is given below:
 How to use NEMA 34 Stepper Motor

As shown in wiring diagram there are four wires of different colours i.e. Red, Green, Yellow and Blue. These wires are connected to two different coils. Red and Green connected to one coil while Yellow and Blue are connected to other.

To rotate the motor coils are energized in a logical sequence. To rotate the motor in anticlockwise motion of the rotor the phases are energized in the following sequence +A, +B, -A, -B, +B, +A and for the clockwise rotation, the sequence is +A, -B, +B, +A……..


Stepper Motor Applications
CNC machines
Precise control machines
3D printer/prototyping machines (e.g. RepRap)
Laser cutters
Pick and place machines


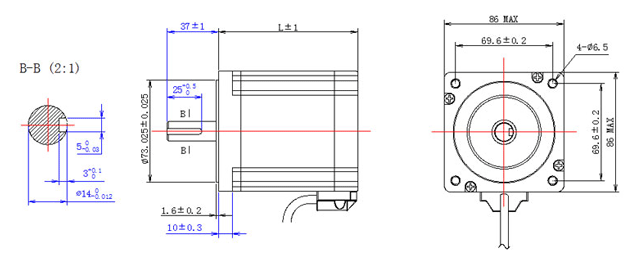
NEMA 34 Stepper Motor Dimensions

NEMA 34 Stepper Motor Dimensions

See more:

https://www.oyostepper.com/article-1091--NEMA-34-Stepper-Motor-Applications-and-Dimensions.html

Tuesday, October 22, 2019

Stepper Motor Heating And Power Supply Voltage


There are two major causes of hybrid stepper motor heating: copper losses and iron losses. Copper losses are the easiest to understand; this is the heat generated by current passing through a resistance, as in the current passing through the motor’s winding resistance. Often this is referred to as “I2R” dissipation.

This cause of motor heating is at a maximum when the motor is stopped and rapidly diminishes as the motor speeds up since the inductive current is inversely proportional to speed.

Stepper Motor Heating And Power Supply Voltage

Eddy current and hysteresis heating are collectively called iron losses. The former induces currents in the iron of the motor while the latter is caused by the re-alignment of the magnetic domains in the iron. You can think of this as “friction heating” as the magnetic dipoles in the iron switch back and forth. Either way, both cause the bulk heating of the motor. Iron losses are a function of AC current and therefore the power supply voltage.

As shown earlier, motor output power is proportional to power supply voltage, doubling the voltage doubles the output power. However, iron losses outpace motor power by increasing non-linearly with increasing power supply voltage. Eventually the point is reached where the iron losses are so great that the motor cannot dissipate the heat generated. In a way this is nature’s way of keeping someone from getting 500HP from a NEMA 23 motor by using a 10kV power supply.

At this point it is important to introduce the concept of overdrive ration. This is the ration between the power supply voltage and the motor’s rated voltage. An empirically derived maximum is 25:1, meaning the power supply voltage should never exceed 25 times the motor’s rated voltage or 32 times the square root of motor inductance.

Check here more “steppermotor for sale”.

Manufacturing principles of right angle planetary gearboxes

1.Basic concepts of  a right angle planetary gearbox A right angle planetary gearbox is a speed reducing transmission system that combines ...