Thursday, December 13, 2018

What is pole count of stepping motor?

Simply defined, a pole is a north or south magnetic field of force that is generated by a permanent magnet or current passing through a coil of wire. For stepper motors, however, this definition does not necessarily translate to a simple definition of pole count. Different manufacturers use different names to refer to their poles and various stepper-motor types have varying kinds and numbers of poles.

The motor drive energizes stator teeth one after the other to make the rotor turn, thanks to its magnets’ tendency to force alignment with the stator teeth.

Permanent-magnet stepper motors online are the simplest. Manufacturers define their pole count by the number of pole pairs or stator windings. Increasing the number of pole pairs on the rotor itself (or adding more stator phases) increases resolution. Most permanent-magnet steppers have a resolution of 30° to 3° per step.

Variable-reluctance and hybrid stepper motors have teeth on their rotors, and stators define pole count. These types of stepper motors move 1.8° or less per step.

• For variable reluctance, the more teeth, the greater pole count, the greater the resolution. Rotation step angle is half that of a permanent-magnet stepper motor with the same number of stator windings.

• In contrast, hybrid stepper motors have rotors covered by two radial sections (cups) of magnetized teeth, with a gap in between them. The two cups have teeth that are offset by one tooth in relation to the other. Here too, the greater number of teeth, the greater number of poles, the higher the resolution and the smaller the steps. This means it can rotate a very small amount (See FAQ: What are hybrid stepper motors?) because of its pole count.

This can influence design decisions in a few ways. Basically, the more poles, the more precisely a drive can control stepper motor output. Beyond this simple fact, manufacturers offer varying arrangements and numbers of stator poles and teeth. Designers must consider the application’s required precision, pole and teeth count, design speed, torque, acceleration, and other parameters. Because pole count affects torque as well, it can lead to design decisions related to inertia matching as well (For more on inertia matching, see FAQ: How do stepper motors handle inertia mismatch?) One last note: because the angle of step affects motor vibration and noise, designers should keep that motor feature in mind when making decisions about pole count.

Tuesday, December 11, 2018

How to Control a Stepper Motor with Your Muscles

Background
Designed and written by José Enrique López Pérez, student of Electronic Engineering in Oaxaca, Mexico.

Where can we find a stepper motor? Instead of buying one, you can also get a stepper motor by opening up an old printer. These motors are generally used in devices controlled by digital systems, like robotics, automation, and, of course, our favorite, 3D printers!

How to Control a Stepper Motor with Your Muscles


What are advantages of Stepper motors?() The axis of a stepper motor rotates at regular intervals instead of doing it continuously like DC (direct current) motors. A Stepper Motor is programmed by a micro controller and can be used for precise positioning within a wide range of applications. Precise positioning of a DC motor is not possible by simple methods.

How does a stepping motor work? The stepper motor is known for its ability to convert a train of input pulses (typically square wave pulses) applied to its coils, into a precisely defined increment of movement in the shaft's position. Each pulse moves the shaft through a fixed angle. This is called a step, hence the name stepper motor. The result of this movement is fixed and repeatable, allowing accurate and reliable positioning.

Why are there so many cables in a Stepper Motor? Unipolar Stepper motors can have 5, 6 or 8 terminals that connect to magnetic coils that allow precise positioning, in addition to other cables such as power and ground.

Circuit of Stepper Motor

How to Control a Stepper Motor with Your Muscles


How is a Stepper Motor different from a DC Motor?

A DC (direct current) motor moves continuously, without steps. It´s used when its important to continually regulate the velocity of a motor. These are the common motors you find in radiocontrol cars and other toys.

A DC motor has two terminals, (+) and (-). Electric current is generated through this terminals making the motor spin in a determinate direction.

How to Control a Stepper Motor with Your Muscles


What are the acceleration requirements of step motor?


Wednesday, December 5, 2018

What is the diagram of a stepping motor?

A best stepper Motor for sale is basically a synchronous Motor. In stepper motor there is no brushes. This motor does not rotate continuously, instead it rotates in form of pluses or in discrete steps. Thats why it is called stepper motor.
The principle of Working of stepper motor is Electro-Magnetism.
The Stepper Motor is of following types:
  • Permanent Magnet
  • Variable Reluctance
  • Hybrid Stepper Motor
1.Permanent Magnet Stepper motor
2.Variable Reluctance Stepper motor
3.Hybrid Stepper Motor

Friday, November 30, 2018

High Responsiveness and Excellent Synchronization of Stepper Motor

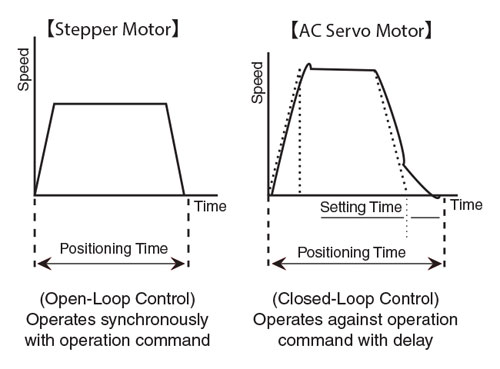
The third remarkable feature of stepper motors best is responsiveness. The open-loop control, which sends one-way commands to the motor, has a high followup mechanism toward commands. While servo motors, which wait for feedback from the encoder, tend to have "delays" with commands, stepper motors operate synchronously with a pulse. Therefore, there are very few "delays," resulting in excellent response. For this reason, stepper motors are suitable for applications that require synchronous operations of multiple motors. One example is a board transferring application that requires two conveyors, with one motor mounted respectively, to transfer boards in between the two conveyors.

Point 2
Excellent Low / Mid-Speed Range!
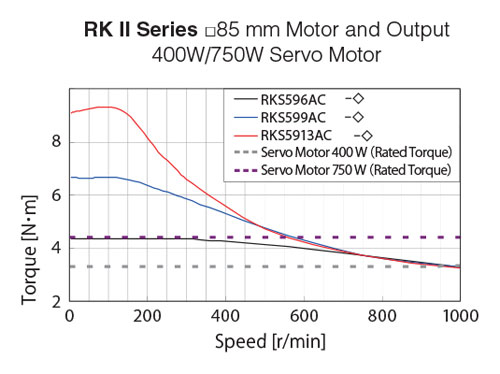
Example: Torque of a motor frame size 85 mm is equivalent to a rated torque of a 400 W servo motor when 1000 r/min.

Torque in an even lower speed range can be up to 5 times higher. For a shortdistance positioning, having high torque in the low / mid-speed range is essential.
RKII Torque Chart
Stepper Motor Open Loop vs Servo Closed Loop

Wednesday, November 28, 2018

Driving a unipolar stepper motor with the NXP PCA9537

The NXP PCA9537 is a 10-pin CMOS totem pole GPIO with an SMBus and I2C two-wire bus so it can interface to most microcontrollers (Figure 3).


Figure 3: The NXP PCA9537 is a totem pole GPIO that takes the I2C byte sequences from the host controller and provides the requisite waveforms to the gate inputs G1 through G4. (Image source: NXP)

In the diagram, the motor is a 12-V unipolar nema 23 stepper motor with a current rating of 1.25 A. For users that want to modify the diagram and tweak it to their own application, there is a fully interactive schematic of the unipolar driver available on Schematics.com.

The PCA9537 has a 4-bit configuration register, 4-bit input port register, and a 4-bit output port register, and a 4-bit polarity inversion register for “active high” or “active low” operation. The GPIO has a fixed I2C-bus slave address of 92H and it takes the I2C byte sequences from the host controller and provides the requisite waveforms to the gate inputs G1 through G4.

The diagram also shows the NXP PCA9665, an IC that serves as an interface between most standard parallel-bus microcontrollers/microprocessors and the serial I2C-bus allowing the parallel bus system to communicate bidirectional with the I2C-bus. The type of waveform will be one corresponding to wave, two-phase or half-step drive, as chosen by the user. The duration of the pulses is controlled by time delay implemented in the host controller firmware. It is shown as a reference for the various waveforms. The maximum I2C-bus speed supported by PCA9537 is 400 kHz.

To drive the stepper motor best price at approximately 18 RPM, use the following byte sequence, where ‘S’ stands for I2C-bus START condition, and ‘P’ stands for STOP condition. Also, DLY1 and DLY2 are time delays implemented by the microcontroller firmware. Numbers are represented in hexadecimal notation:

S, 0x92, 0x03, 0x00, P // Set all 4 IO pins of PCA9537 as OUTPUT pins;
// IO Configuration Register = 0x00
Set DLY1 = 300 ms // Time delay between steps; 18 RPM for a 7.5˚ motor

//Start of waveform loop
S, 0x92, 0x01, 0x08, P // Start the half-step sequence waveform
Execute time delay between steps = DLY1
S, 0x92, 0x01, 0x0C, P // outputs for the next step
Execute time delay between steps = DLY1
S, 0x92, 0x01, 0x04, P // outputs for the next step
Execute time delay between steps = DLY1
S, 0x92, 0x01, 0x06, P // outputs for the next step
Execute time delay between steps = DLY1
S, 0x92, 0x01, 0x02, P // outputs for the next step
Execute time delay between steps = DLY1
S, 0x92, 0x01, 0x03, P // outputs for the next step
Execute time delay between steps = DLY1
S, 0x92, 0x01, 0x01, P // outputs for the next step
Execute time delay between steps = DLY1
S, 0x92, 0x01, 0x09, P // outputs for the next step
Execute time delay between steps = DLY1
// Loop through waveform sequence to keep running motor
// OR execute next two steps if desired
Execute time delay = DLY2 // Hold in current position for time = DLY2
S, 0x92, 0x01, 0x00, P // Turn off motor

(Byte sequence source: NXP)
Of course, some users may want to drive multiple motors. For this, many single-chip options are also available. In the meantime, it’s good to practice on the PCA9537 and the unipolar, single-motor, interactive schematic shown here.

Saturday, November 24, 2018

A Simple Approach to Driving The Ubiquitous Stepper Motor

Stepper motors for sale are a favorite of designers, engineers, and makers alike, and so can be found almost everywhere there is an electronically controlled system. They’re so popular and useful, in fact, that it’s often easy to forget how they work and to ensure that they are being driven correctly.

The motors themselves are brushless, synchronous DC motors where each 360˚ rotation is divided into a number of equal, discrete steps. The angular rotation of step is determined by the number of “toothed” electromagnets arranged around a central, gear-shaped piece of iron (Figure 1). It is the energization of the magnets, and the ensuing magnetic attraction of the gear-shaped shaft’s teeth, that pulls the shaft around its axis of rotation by.


Figure 1: The permanent-magnet rotor is rotated according to the sequencing of the pulses applied to energize the electromagnetic “teeth”. (Image source: NXP)

It’s important to note that when the shaft’s teeth are aligned with the first electromagnet, they are slightly offset from the next electromagnet. This makes sure that when the next electromagnet is energized, the teeth are pulled in the direction of the next electromagnet.

The number of steps required to complete a single 360˚ revolution defines its resolution, or how finely the motor can be controlled. Typical motors have 200 steps per revolution, but it’s not unusual to see 1600 steps per revolution for very fine control of movement, such as the arm of a hard disk drive.

Control is accomplished using a sequence of square digital pulses, typically from a microcontroller, which are used to intelligently drive the coils. The word “intelligently” is deliberate here: as how the coils are arranged, constructed and driven determines key parameters such as efficiency, accuracy, precision, repeatability, and torque. Each pulse is a discrete step and so the number of pulses and their rate determine the rotation distance and speed.

Depending on how the coils are connected and driven, steppers can be either unipolar or bipolar. In unipolar designs, the current flow is always in the same direction to achieve rotation. In bipolar nema 17 geared, an alternating reversal of current flow in the windings is used to achieve rotation.

Some of the interesting, useful and fun characteristics of stepper motors include that fact that once energized, it stays rock steady with full torque until the next pulse; the precision with which they can be controlled, particularly if gearing is used; the fact that they can be reversed quickly by changing pulse polarity, manually or electronically; their fast-stop capability; robustness and reliability; and low cost.

Adding to the cost and simplicity factor is the fact that they are open loop. This means that there is no need for extra sensors or feedback mechanisms to determine the shaft position.


Thursday, November 15, 2018

Effective way to prevent step losses of stepping motor

The use of stepper motors is an excellent choice. However, a key concern is step losses. Step losses can be prevented or corrected in most instances.

Image result for Effective way to prevent step losses of stepping motor

How to prevent step losses with Stepper Motors
Stepper motors operate open loop.  When a stepping motor does not operate correctly in a specific situation, the common conclusion is that either the motor or the drive electronics is faulty. The motor selection and the choice of the driver are critical.  However, other factors contribute to step losses.
The following points are important to examine for the analysis of step losses or non-operation in a methodical fashion across a variety of applications:

A. Stepper Motor Selection
B. Motion profile
B1. Start-Stop operation
B2. Trapezoidal profile
C. External commutation errors
D. External events
D1. Back driving
D2. Increase of the pay load over time

A. Stepper Motor Selection
The first task is to select the right step motor best price for the application. For the best selection, those basic theoretical rules have to be respected:
1. Select the motor based on the highest torque/speed point required by the application (selection based on the worst
case)
2. Use a 30% safety factor from the published torque vs.speed curve (pull-out curve).
3. Ensure that the application cannot be stalled by external events.

It is important to remember that a stepper motor does not operate like a DC-motor.  There is no working point parameterization, and the phase current does not increase to overcome variations of load. As long as the speed vs. torque requirement of the application is within the specs of the motor, no problem will be encountered. If this requirement is out of the specs, the motor stalls (OK or NOT OK functionality). In any case, the current in the phases is not changing and adapting by itself to the situation.

Manufacturing principles of right angle planetary gearboxes

1.Basic concepts of  a right angle planetary gearbox A right angle planetary gearbox is a speed reducing transmission system that combines ...